
2.1 Introduction
Definition: The science of motion which treats motion without regard to the forces that cause it.
Trajectory: Position, Velocity and Acceleration.
Link type: Revolute, Prismatic, Spherical, Screw.
2.2Link Connection

讯享网 where N=number of links.
(从空间一点到一点需要6自由度,D-H使用4个参数描述)
Denavit-Hartenberg model (D-H model)
旋转的方向一定是Z方向;
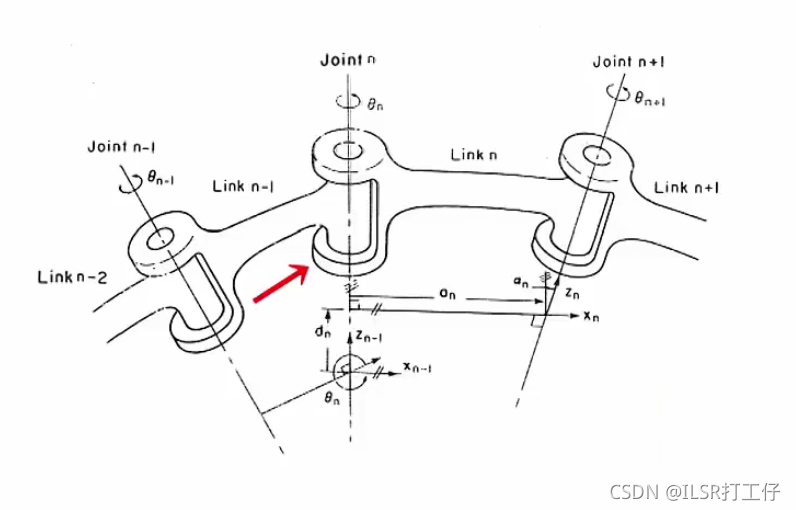
Z放在下一轴的旋转轴;
X是两个Z轴的common normal(公垂),若common normal平行则任意;
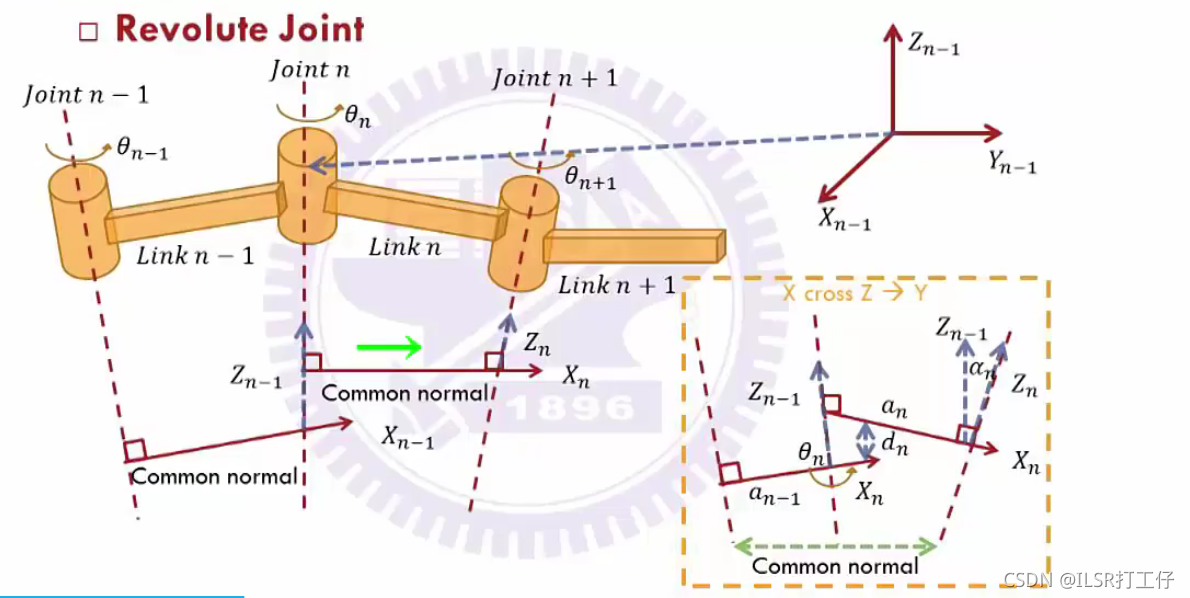
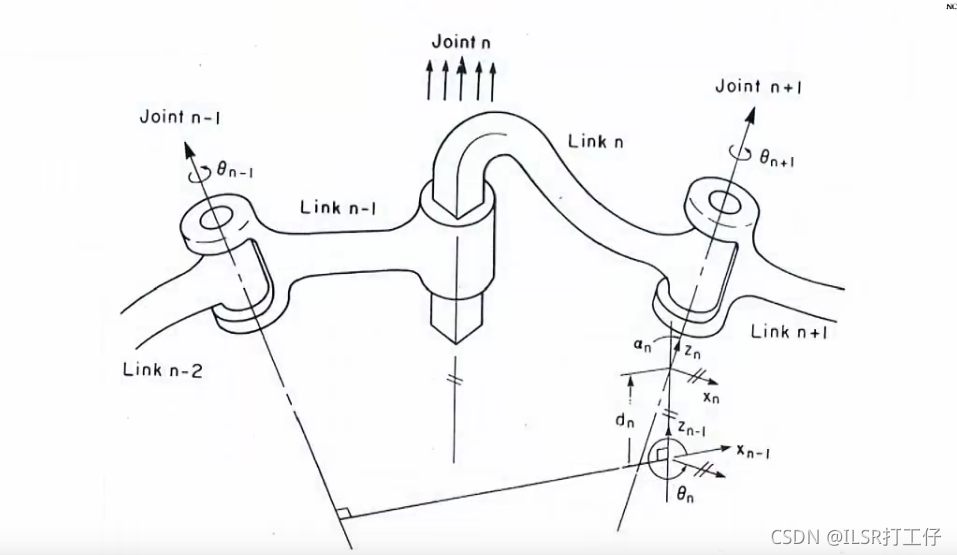
Steps to establish the relationship between two coordinate systems
- 绕z轴旋转一个θ角度;
- 沿着z轴平移一个d的距离;(1、2可换序)
- 沿着新的x轴平移一个a的距离;
- 绕着x轴旋转一个α角度 .
Stanford Arm
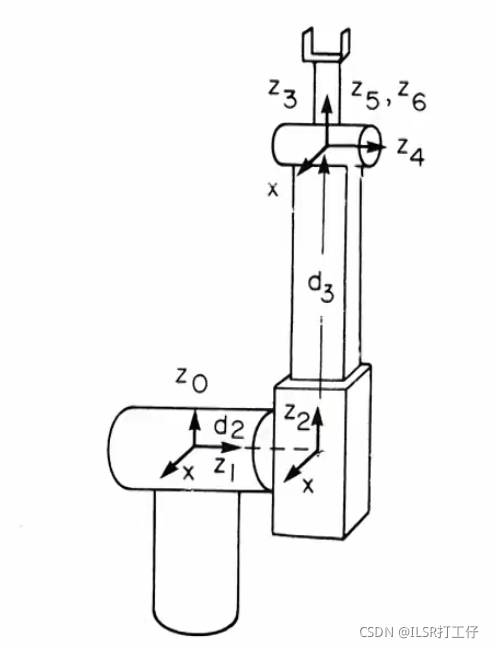
Z6轴是安装在球型轴前端的操作器
Wrist-partitioned;腕臂分割形式,机器人456轴做成球型轴,123旋转/平移轴
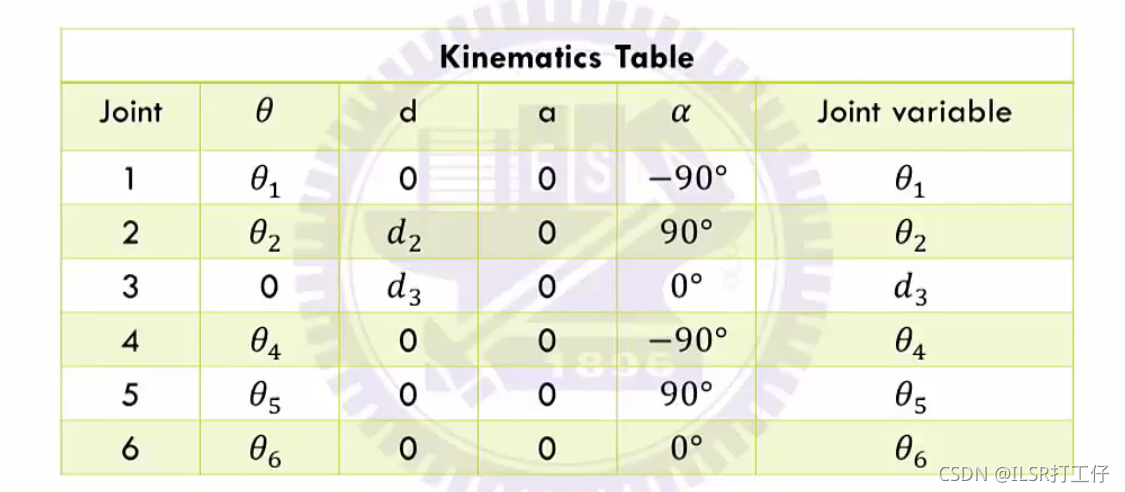
机器人标准矩阵
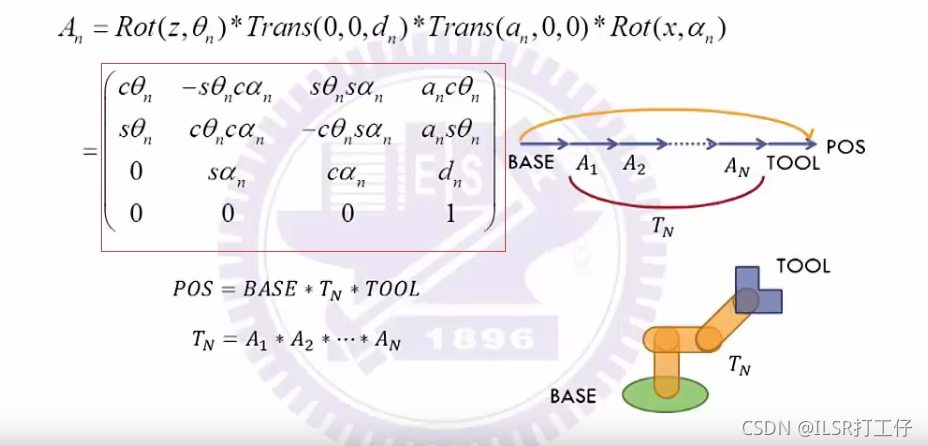
- In the case of prismatic joint,the origin of the coordinate frame for a prismatic joint is coincident with the next defined link origin.
- The zero position is defined when d=0 a=0
- An matirx is reduce to:
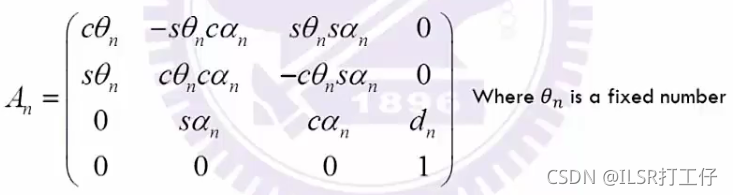
相比较上一个D-H标准矩阵平行轴的D-H矩阵的a恒等于0,α和θ等于0、90、180
注:
旋转轴θ是变化量;
平移轴d是变化量;
平移轴a=0;
初始的坐标系中d=0。
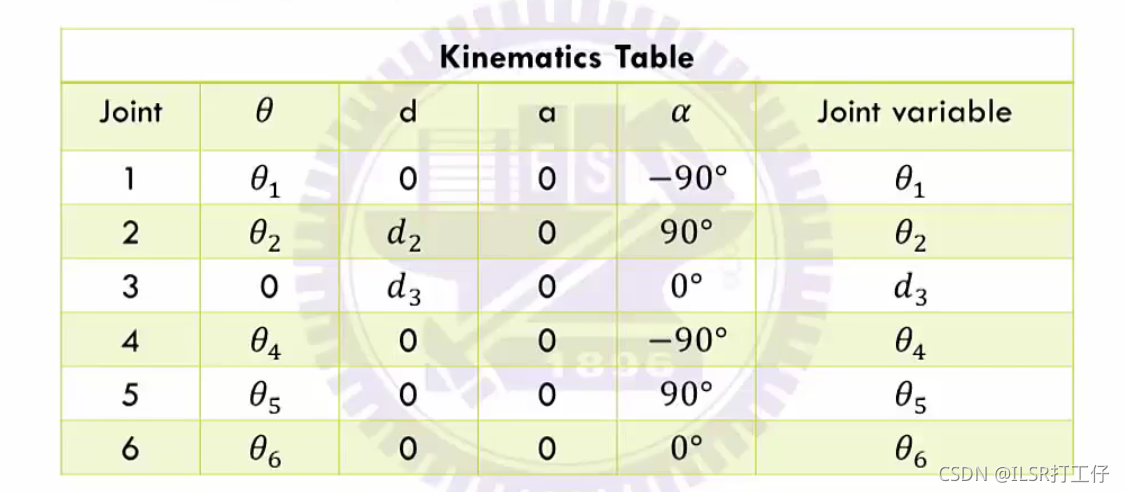
将1的参数带入标准的D=H矩阵
3是平移轴变量只有D;
456球型轴没有d;
2.3 Example for Kinematics
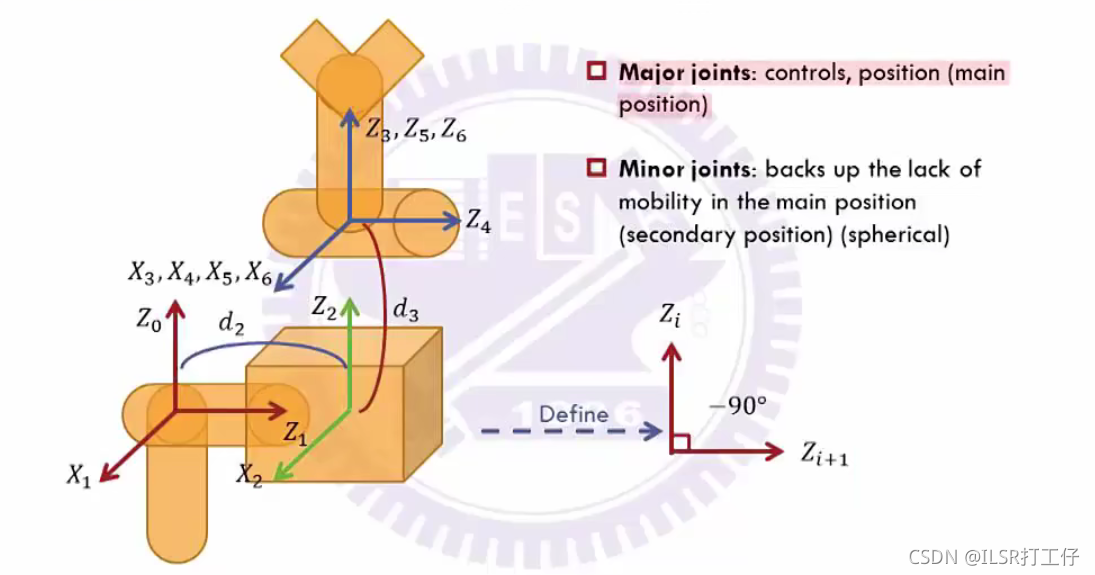
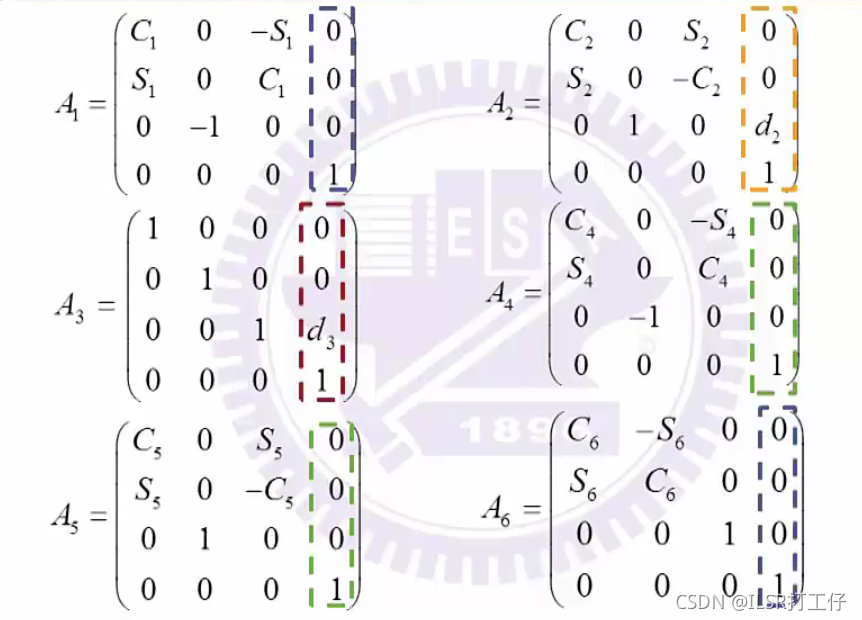
PUMA
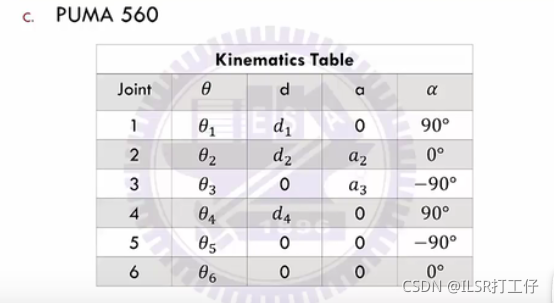

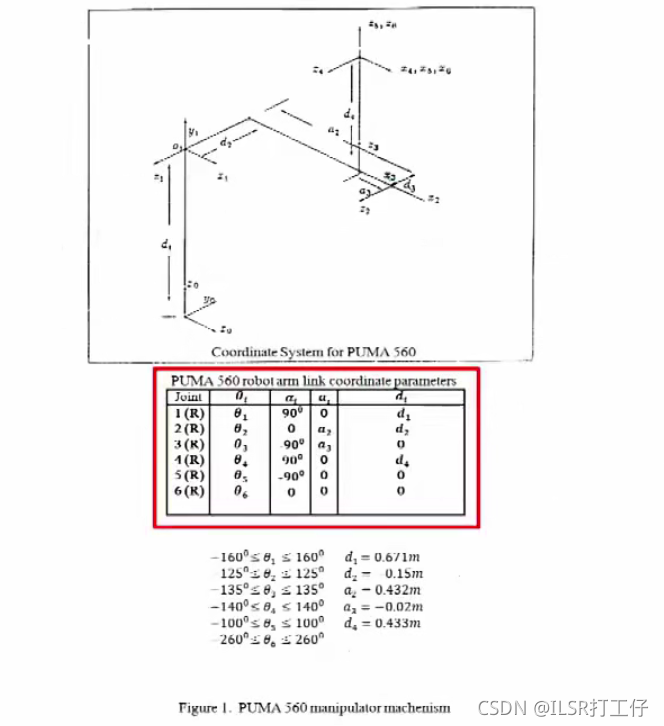
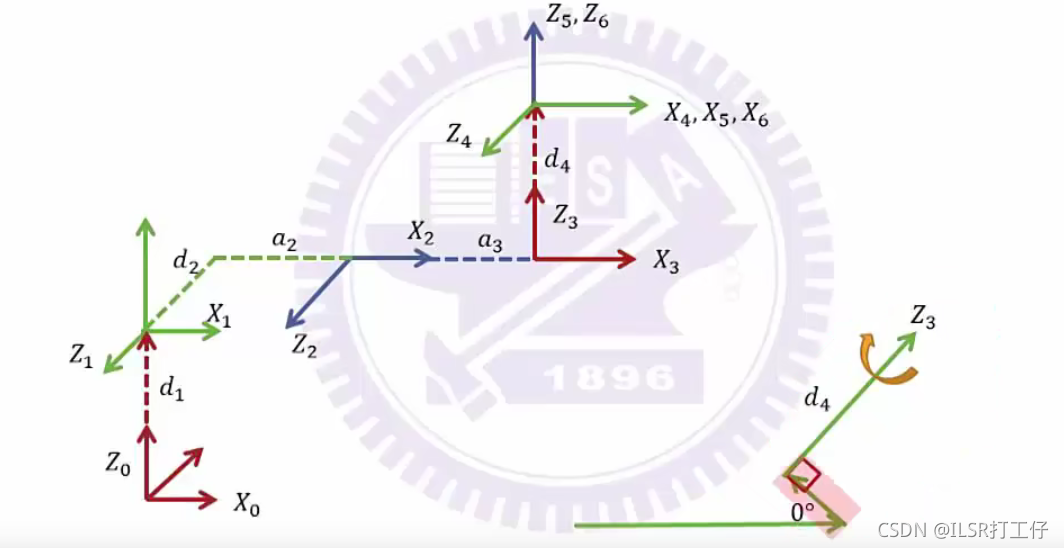
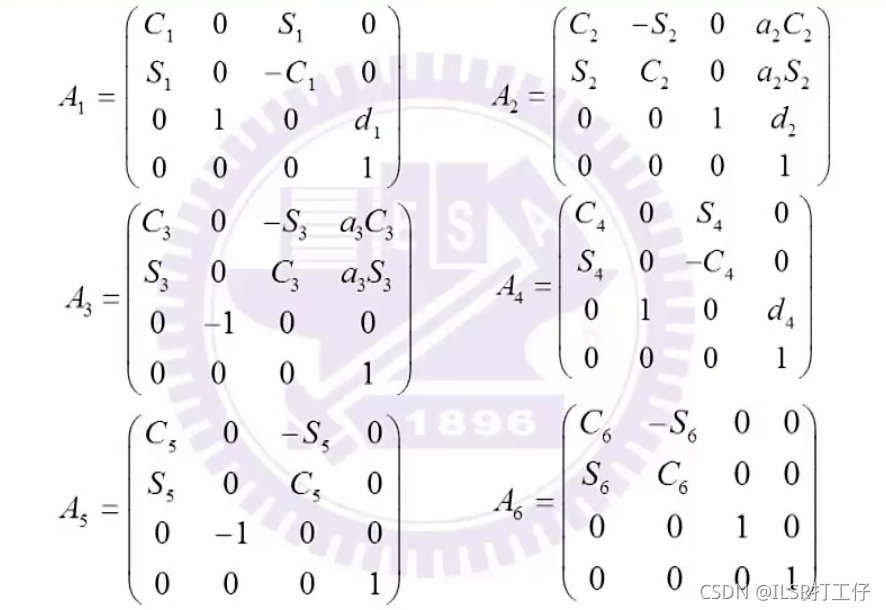
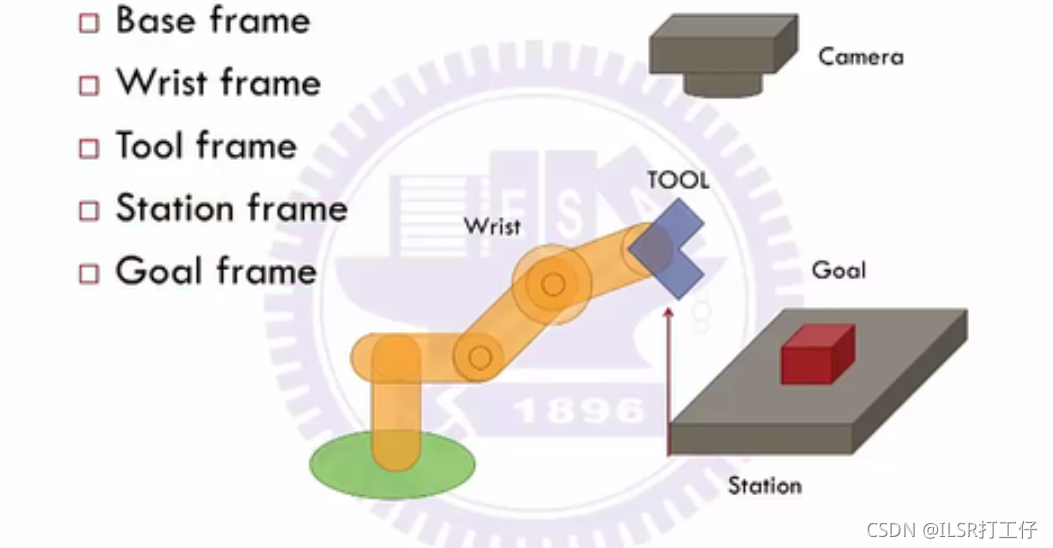
2.4 Frame of Convention
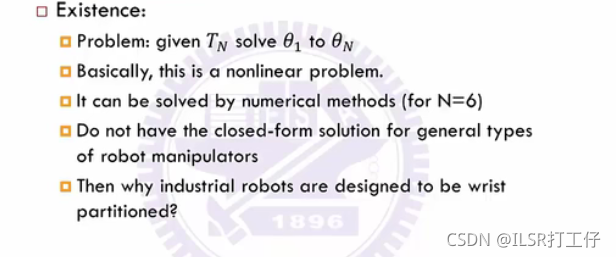
给定TN求θ1-N
2.5Inverse kinematics
Workspace:
The volume of space which the end-effector of the mainpulator can reach
Dexteruos Workspace:
The volume of space which the robot end-effector of the mainpulator can reach with all orientations
Reach Workspace:
The volume of space which the end-effector of the mainpulator can reach in at least one direction
For instance
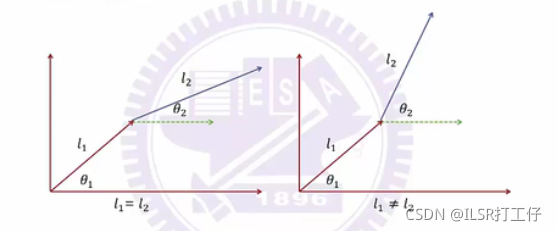
Configuration
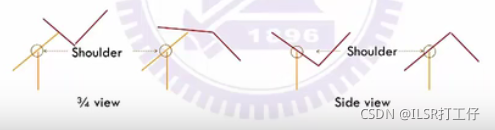
A position may be reached with different configurations

PUMA Case
For ways to reach the same wrist position. Another two configurations are present in the minor joints.
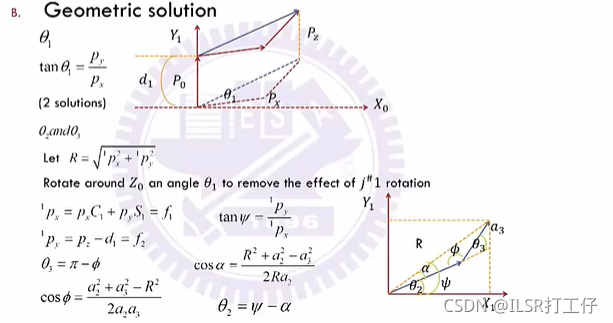
两种逆运动学解法,数值方法与几何方法:
数值方法:
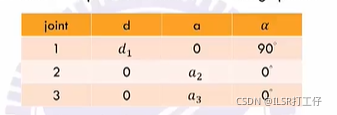
给出三轴机器人的D-H表
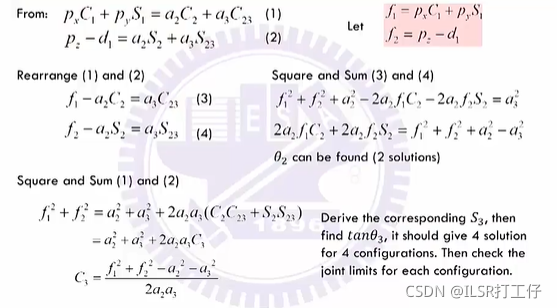
用过A1-3相乘与workspace中的一noap相等计算各轴的旋转角度
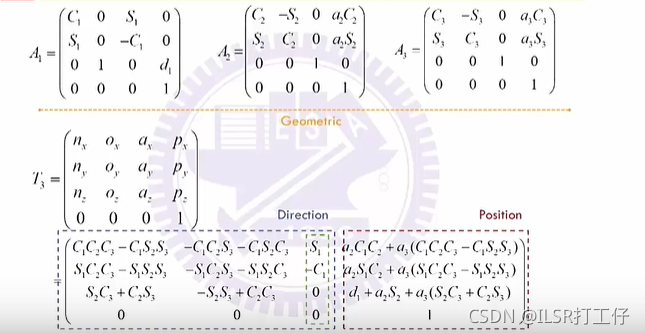
解前三轴的解释正能用第4 列的对应相等求解

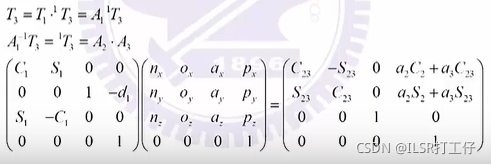
几何法;
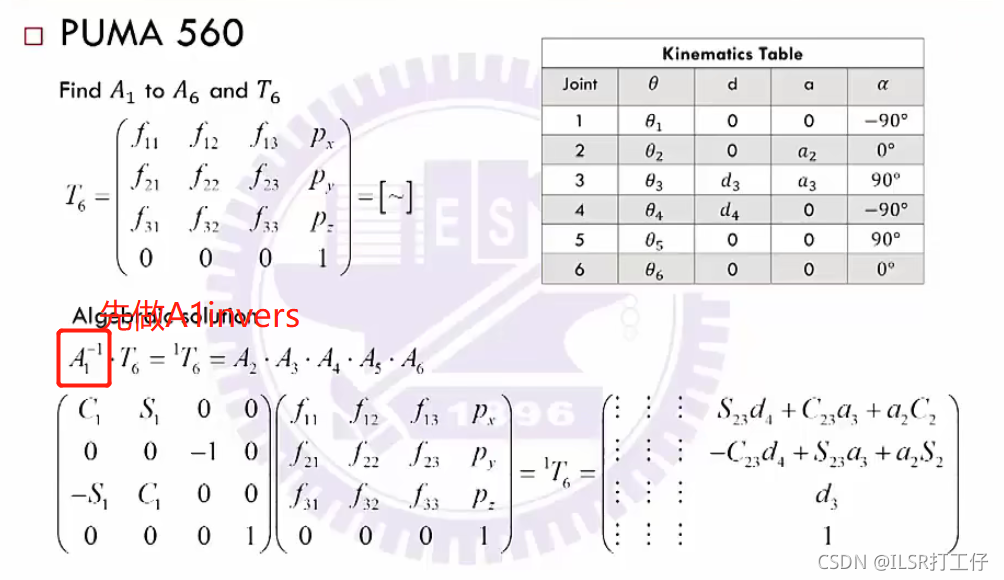
2.6 PUMA 560
wrist partition type
primary joins(前三轴):for the positional workespace
minor jiont(球型轴):for the orientation workpace

Atan2(x,y),用来区分四个象限

保持同一种形式

类似欧拉角解法解球形轴
几何法,切成两个3的问题,在拆成1跟2的问题(不常用)
2.7机器人校正思路-重复定位精度(Repeatability)和精度(Accuracy)
 重复定位精度一定比精度高,若果重复定位精度无法满足需求则需要更换机器人。
校准方法

……
版权声明:本文内容由互联网用户自发贡献,该文观点仅代表作者本人。本站仅提供信息存储空间服务,不拥有所有权,不承担相关法律责任。如发现本站有涉嫌侵权/违法违规的内容,请联系我们,一经查实,本站将立刻删除。
如需转载请保留出处:https://51itzy.com/kjqy/80243.html