
《Key Points Estimation and Point Instance Segmentation Approach for Lane Detection》
论文:https://arxiv.org/abs/2002.06604
代码:GitHub - koyeongmin/PINet
论文解读:http://t.csdnimg.cn/AOV91
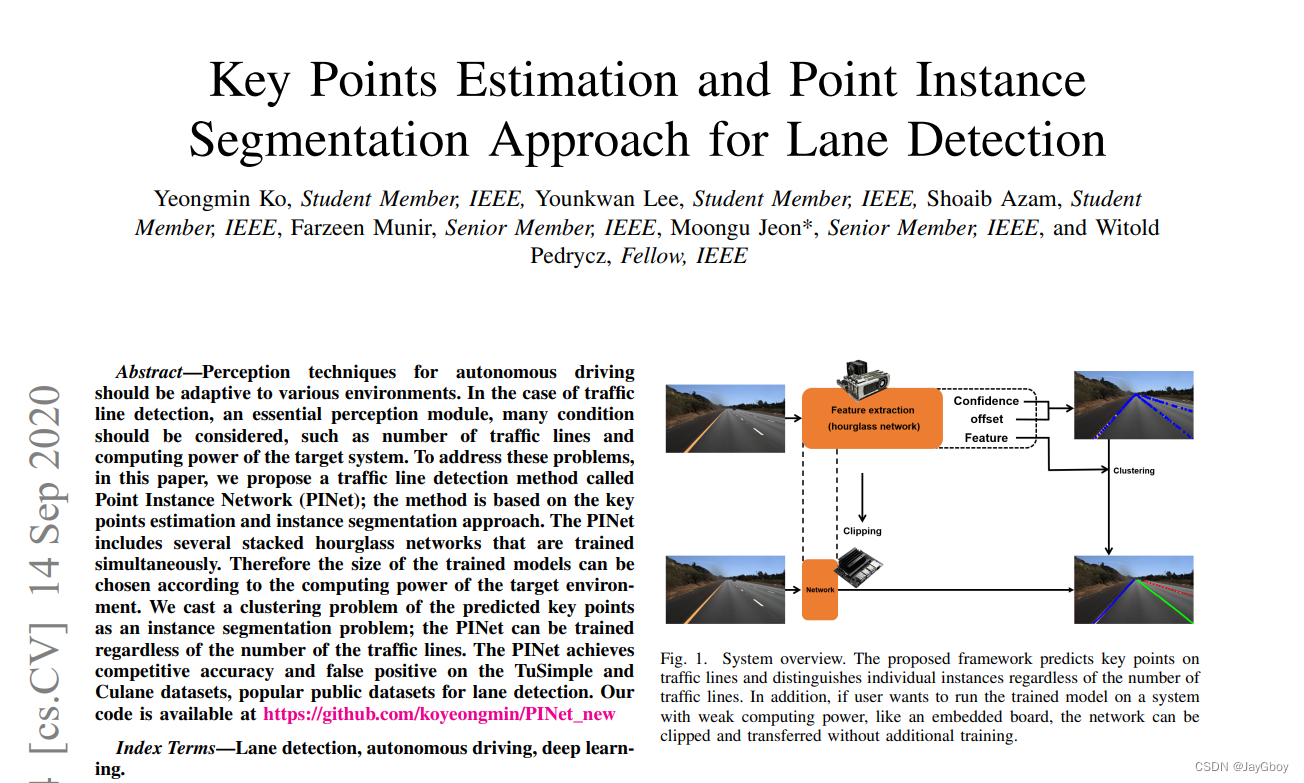
这是篇关于自动驾驶中车道检测技术的研究论文,标题为“Key Points Estimation and Point Instance Segmentation Approach for Lane Detection”,作者包括Yeongmin Ko、Younkwan Lee、Shoaib Azam、Farzeen Munir、Moongu Jeon和Witold Pedrycz。论文提出了一种名为Point Instance Network (PINet)的车道检测方法,该方法基于关键点估计和实例分割方法。
版权声明:本文内容由互联网用户自发贡献,该文观点仅代表作者本人。本站仅提供信息存储空间服务,不拥有所有权,不承担相关法律责任。如发现本站有涉嫌侵权/违法违规的内容,请联系我们,一经查实,本站将立刻删除。
如需转载请保留出处:https://51itzy.com/kjqy/131130.html